MoChest
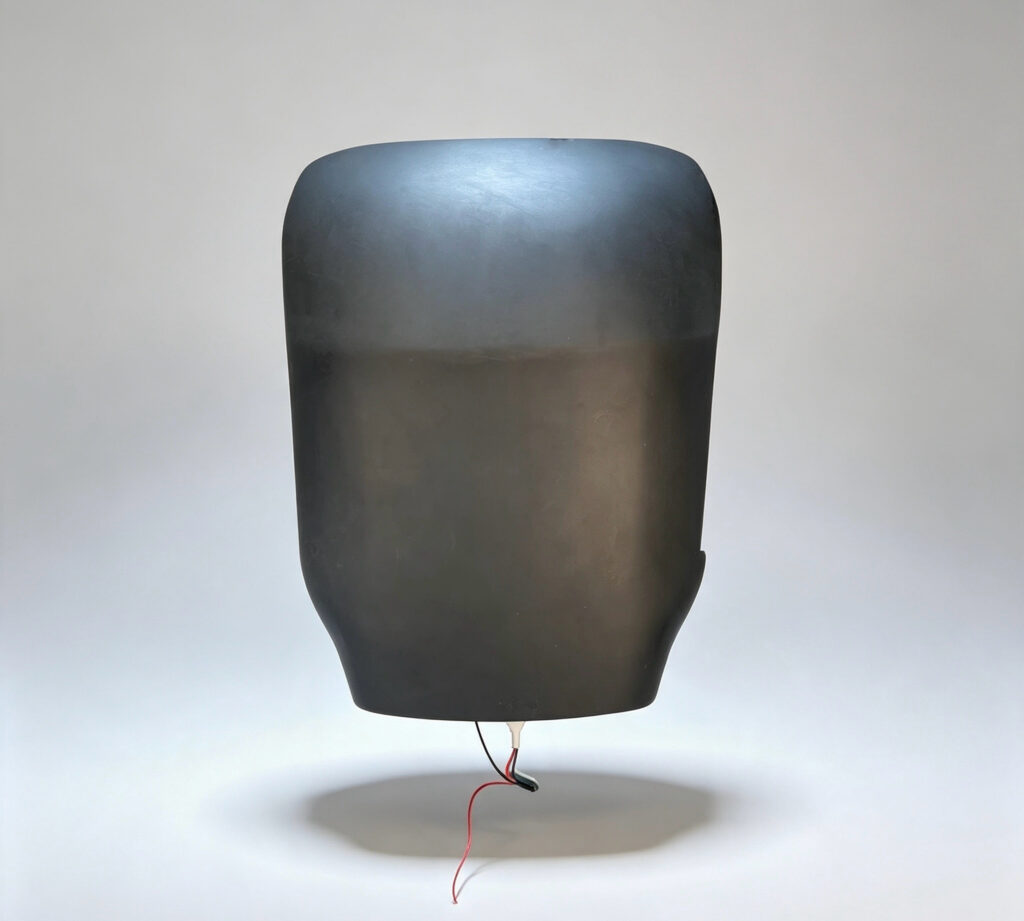
MoChest is a thoracic haptic sensing system designed exclusively for humanoid robots and bionic platforms. Featuring a flexible curved form to fit the contour of a robot’s thoracic cavity, the product uses non-contact magnetic induction array technology to capture real-time force-field distribution data upon contact or proximity on the chest surface. It endows robots with “thoracic haptic perception” and serves as one of the core components of MoSense’s full-body robotic haptic skin solution.
Core Features
High-Density Sensing Array:
A single module covers the main thoracic region, supplying rich multi-dimensional haptic data and supporting refined interactive feedback.
Flexible Curved Conformal Design:
Built with flexible substrates and curved structures to match the thoracic contour of robots, delivering strong visual integration after installation.
Multi-Dimensional Physical Quantity Output:
It outputs temperature compensation data and 3D spatial magnetic field variations simultaneously. Calculated via the host PC algorithm model, intuitive force-field distribution, indentation depth and three-axis force vectors are generated.
Plug-and-Play Ecosystem:
Compatible with MoSense’s unified communication protocol and host software. It can be rapidly integrated into existing robot control systems without complex secondary development.
Application Scenarios
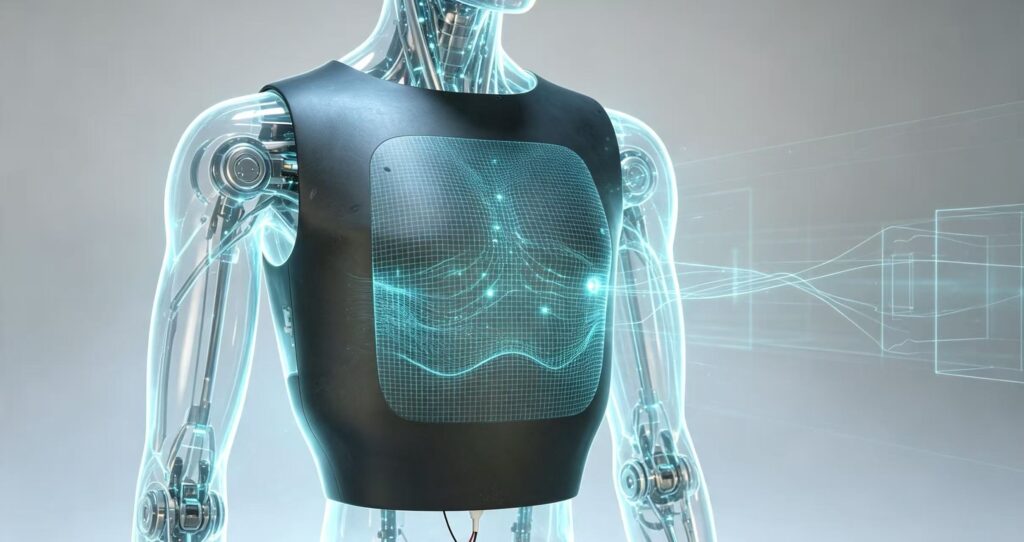
Dynamic Obstacle Avoidance and Compliant Interaction for Humanoid Robots:
A haptic sensing layer is formed on the robot’s chest area to detect obstacle contact or human proximity, enabling active avoidance and compliant responses.
Physical Interaction for Rehabilitation and Care Robots:
It senses pushing, pressing and touching actions applied by patients on the robot’s chest in real time, supporting safe physical human-robot interaction logic.
Service Robot Condition Monitoring:
Detects external impact or abnormal contact, supplying haptic evidence for robot health management and behavioural decision-making.