MoGrip
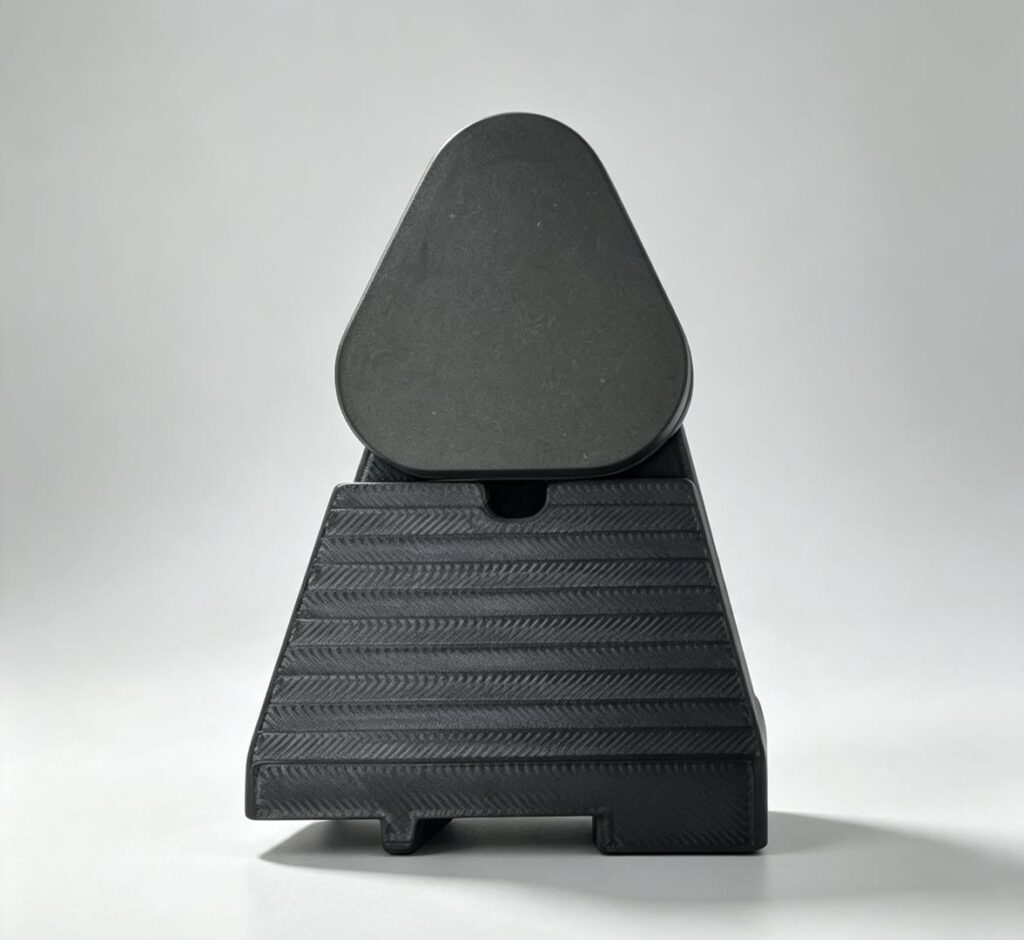
MoGrip is a high-density fingertip haptic sensing system designed for dexterous hands, industrial grippers and bionic end-effectors. Packaged in a miniaturised form, the product integrates an ultra-high-density magnetic induction array and high-speed sampling circuitry. It conforms to the curved contour of fingertips and captures multi-dimensional force-field data from grasping contact surfaces in real time. By predicting the onset of object slippage and sensing contact-point pressure distribution plus three-axis force vectors, MoGrip greatly boosts success rates for delicate grasping and complex manipulation tasks. It serves as a core sensing component for the end-effector stage within MoSense’s full-body robotic haptic skin solution.
Core Features
Ultra-High Array Density and Sampling Rate:
High-density arrangement of sensor dots paired with high-speed data acquisition links ensures fine capture and real-time responses to contact force changes the instant grasping occurs.
Slippage Prediction and Active Anti-Slip Control:
Based on temporal variations of multi-dimensional force fields, the algorithm model anticipates object slippage trends and triggers adaptive force increase or minor pose adjustment of the gripper, drastically cutting grasping failure rates.
Miniaturisation and Curved Conformal Design:
Built with flexible substrates and miniaturised packaging technology, it adapts to the curved structure of fingertips. After mounting, it does not impair the original degrees of freedom of dexterous hands and delivers strong visual integration.
Application Scenarios
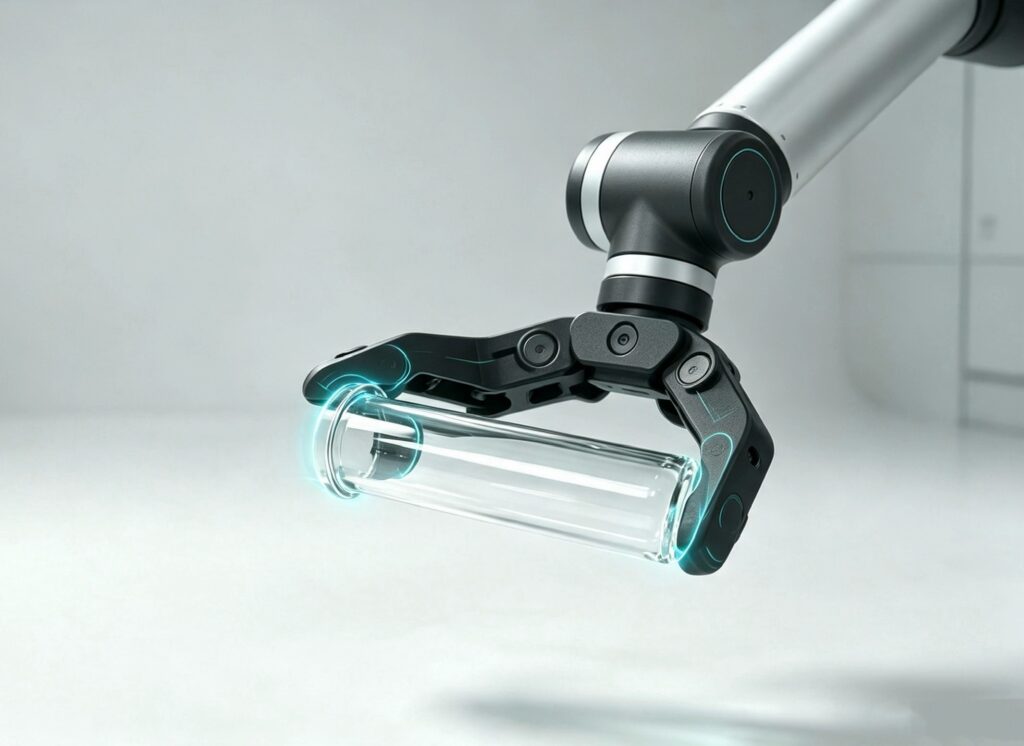
Dexterous Hand Fine Manipulation:
When grasping fragile, slippery and irregular objects such as eggs, glassware and soft workpieces, it detects contact conditions in real time to achieve human-like adaptive force control.
Quality Inspection for Industrial Grippers:
It senses force distribution and slippage trends during grasping, helping judge whether workpieces are properly positioned, tilted or abnormal.
Object Manipulation for Humanoid Robots:
It supplies haptic feedback for hand interaction of humanoid robots and supports sensing and control of complex hand motions including pressing, pushing, pulling and rotation.