MoPad

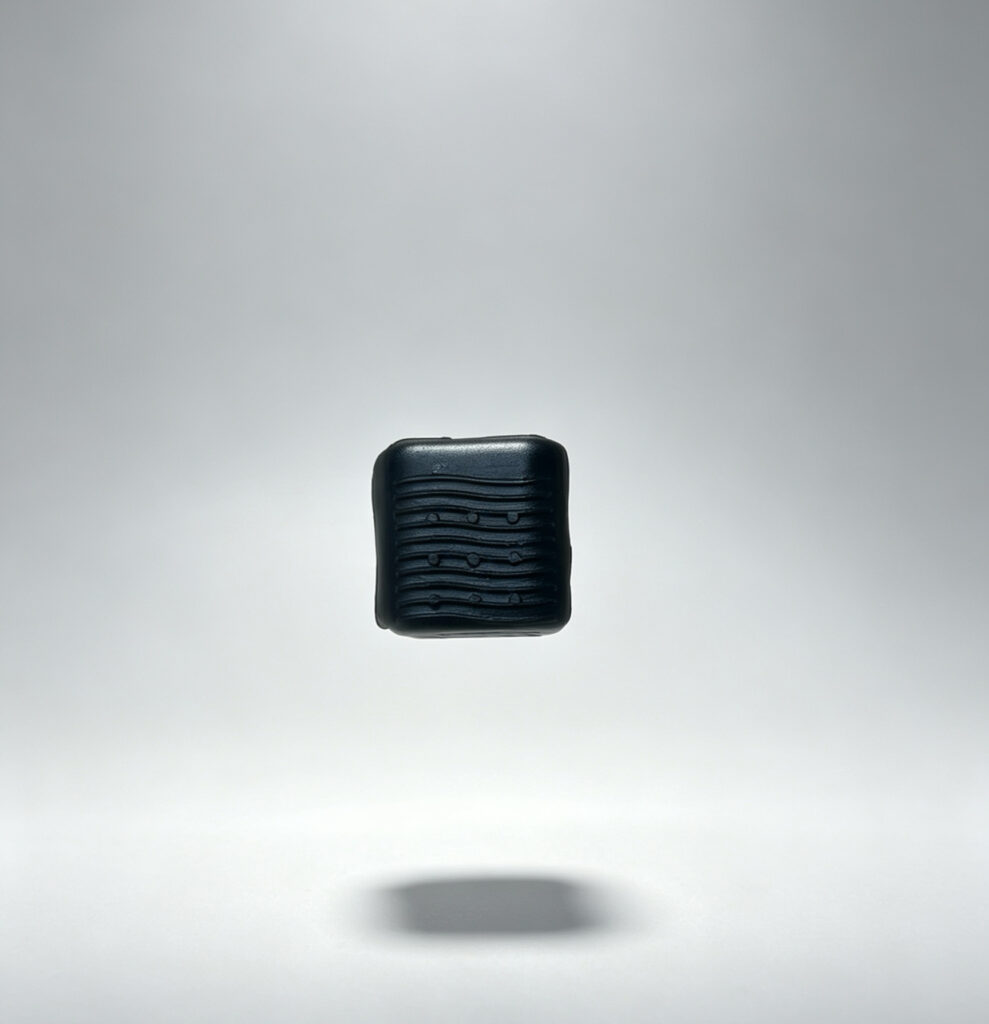
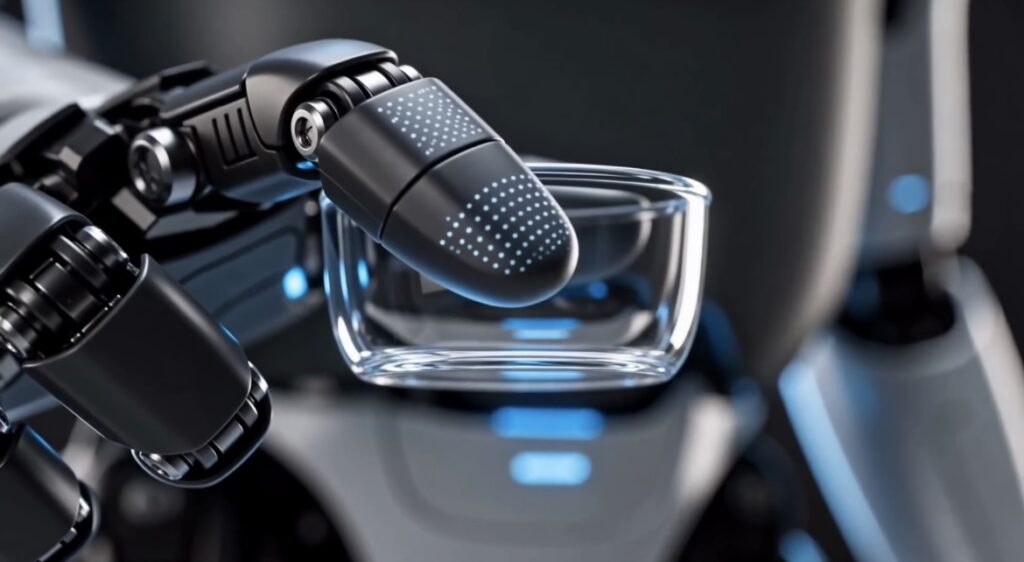
MoPad is a fingertip-pad haptic sensing system designed for robotic hand grasping scenarios. Tailored for large-area contact and load-bearing features of finger pads, the product adopts flexible sensing technology with high-density arrays to capture contact pressure distribution and multi-dimensional force-field data in real time. It endows robots with stable, comprehensive grasping perception and serves as an indispensable part of MoSense’s hand electronic skin solution.

Core Features

Miniature High-Density Array:

High-resolution sensing dots sharply capture object surface texture and subtle contact, eliminating blind spots under minor force.

Multi-Dimensional Pressure Distribution:

It outputs high-resolution pressure distribution maps and three-axis force vectors in real time to quantify overall grasping force precisely.

Dynamic Deformation Conformability:

Premium flexible substrates adapt to surfaces of objects of varying shapes and sizes with outstanding conformability.

Standardised Interface Ecosystem:

Compatible with MoSense’s unified communication protocol and host software. It can be rapidly integrated into existing hand control systems without complex secondary development.
Application Scenarios

Stable Adaptive Grasping:

It detects grasping force and contact area in real time to support safe and stable gripping of objects with varied weights and shapes, preventing slippage or damage.

Human-Robot Interaction and Gesture Recognition:

It identifies contact features such as pressing and pushing on finger pads to enable safe physical human-robot interaction logic.

Hand Condition Monitoring:

Detects external impact or abnormal contact, supplying haptic input for robot hand health management and behavioural decision-making.