MoTip

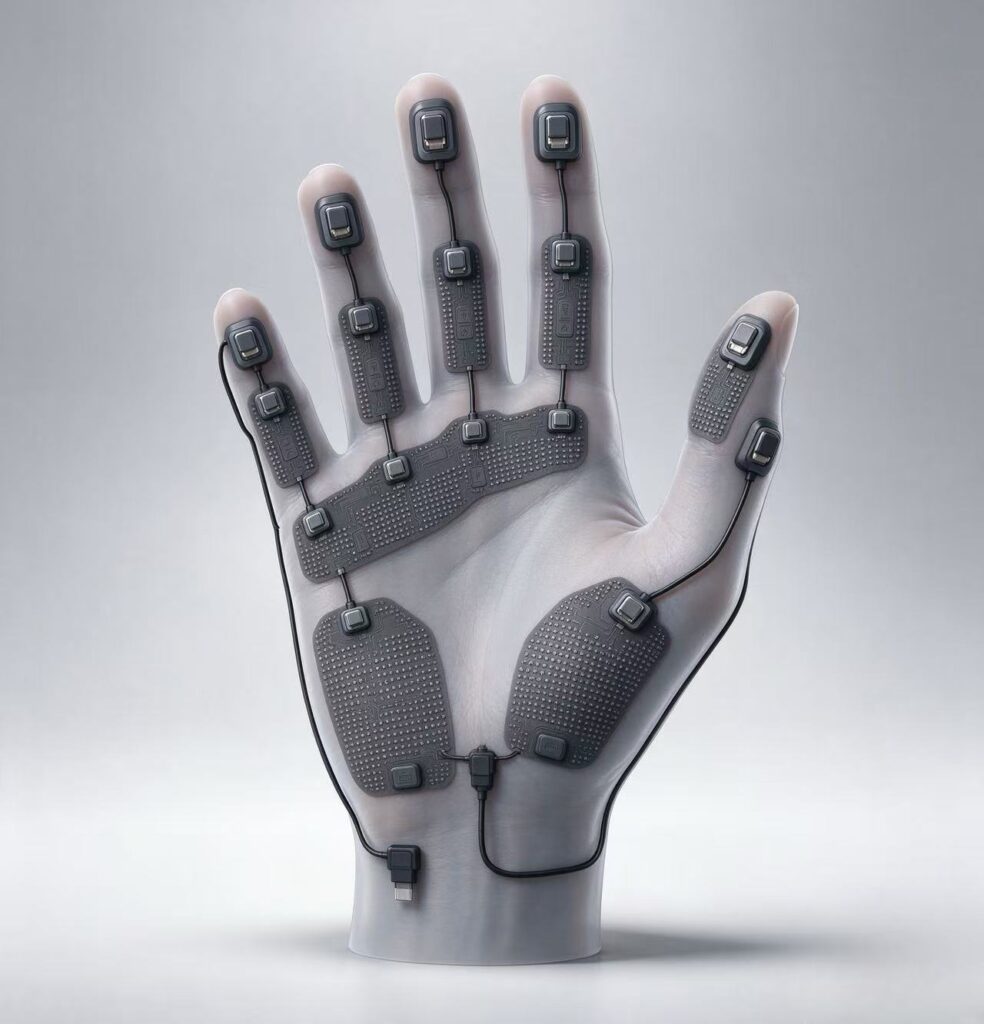
MoTip is a fingertip haptic sensing system designed for robotic dexterous hands and bionic manipulators. Tailored for the demand for extreme fingertip sensitivity, the product adopts a high-density miniaturised sensing array and flexible encapsulation technology to replicate the acute tactile sensation of human fingertips, precisely capturing micro-contact, slippage and 3D force variations. As one of the core components of MoSense’s hand electronic skin solution, it delivers high-precision fingertip haptic feedback for robots.

Core Features

Miniature High-Density Array:

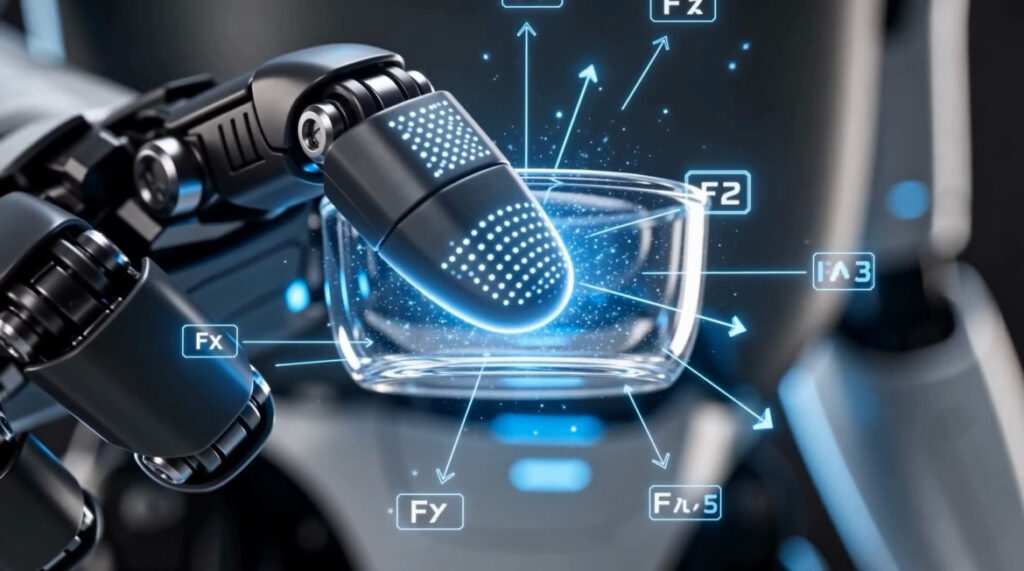
High-resolution sensing dots capture surface texture and subtle contact of objects sharply, eliminating blind spots under minor force.

Multi-Dimensional Force Perception:

Supports detection of three-axis force, friction and slippage, feeding back contact direction and force variations during grasping in real time.

Bionic Curved Encapsulation: Constructed from flexible substrates with bionic curved geometry. It fits fingertip tips perfectly without interfering with the original kinematic structure of dexterous hands.

Low-Latency Rapid Response:

High-frequency data acquisition and transmission meet real-time closed-loop control requirements for complex manipulation.
Application Scenarios

Fine Dexterous Manipulation:

Suitable for grasping tiny, fragile or high-precision components. It delivers real-time micro-force feedback to prevent excessive applied force.

Surface Texture Recognition:

It detects surface roughness and material characteristics of objects, supplying multi-modal haptic data for robot recognition and decision-making.

Slippage Prediction & Control:

Friction sensing anticipates object slippage trends and dynamically adjusts grasping force in real time to avoid slip-off.